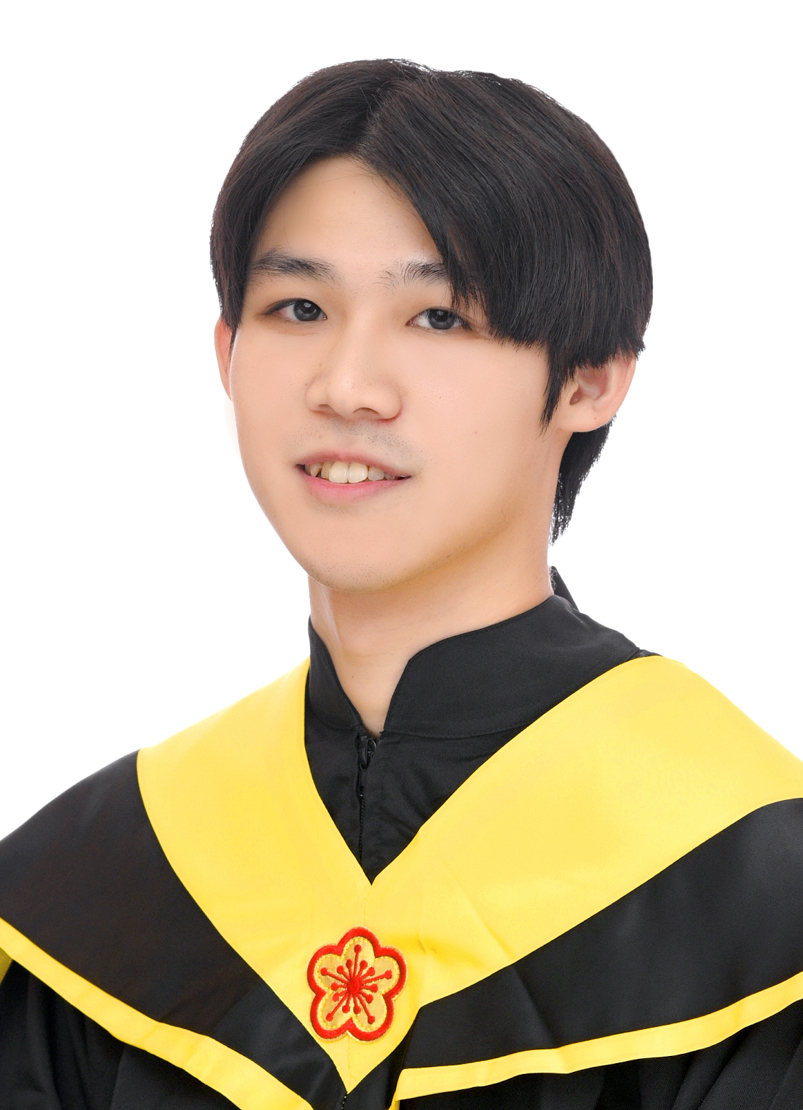
About Wei-Hsuan
Hi, this is Wei-Hsuan Cheng (he/him). I am a robotics researcher (Associate Researcher) at Delta Robotics Innovation Center (DRIC), where I focus primarily on model-based control and estimation methods (e.g. force control, kinematics/dynamics MPC, KF-family) across various robotic embodiments, including dual-arm systems, dexterous hands, mobile manipulators, and integrated combinations of these platforms.
Previously, I completed my Master’s degree at Robots and Medical Mechatronics Lab (RMML), Department of Biomechatronics Engineering, National Taiwan University (NTU), advised by Prof. Ping-Lang Yen.
- Master’s thesis title: “Application of Vision- and Force-Based Supervisory Teleoperation for Robotic Dexterous Manipulation Tasks in Industrial Surveillance”
My research interests lie in robotics, particularly model-based control and estimation for manipulation and legged/wheeled-legged locomotion. I have experience in diverse domains in robotics, including but not limited to
Compliance control(force, admittance, and impedance control)Model predictive control (MPC)(kinematics and dynamics MPC, whole-body inverse-dynamics MPC)Whole-body control (WBC)Kalman filtering(KF, EKF, UKF, InEKF, etc.)Teleoperationrobotic system throughwireless communication- Robotic
dexterousmanipulations (contact-rich, physical interactions, compliant motions, etc.) - Robotic arm
vision-based control(visual servoing, 6D pose estimation and tracking) - Application of
geometric algebrain robotics
Check out my projects and resume here. Reach out if you’re intereted in what I’m doing!